Publications
Peer-reviewed papers, talks, and reports.
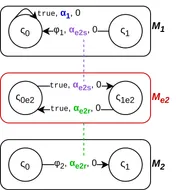
AS2FM: Enabling Statistical Model Checking of ROS 2 Systems for Robust Autonomy
Christian Henkel, Marco Lampacrescia, Michaela Klauck, Matteo Morelli @ IROS 2025
Execution Semantics of Behavior Trees in Robotic Applications
Towards Robust Autonomous Robots Using Statistical Model Checking
Towards a Verifiable Toolchain for Robotics
Results of the ROSCon24 Workshop Survey ‘Hands-on with ROS2 Deliberation Technologies
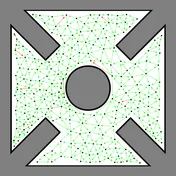
GSRM: Building Roadmaps for Query-Efficient and Near-Optimal Path Planning Using a Reaction Diffusion System
Christian Henkel, Marc Toussaint, Wolfgang Hönig @ IROS 2024
Ant colony optimization based multi-robot planner for combined task allocation and path finding
Optimized directed roadmap graph for multi-agent path finding using stochastic gradient descent
Christian Henkel, Marc Toussaint @ SAC 2020
An optimal algorithm to solve the combined task allocation and path finding problem
Christian Henkel, Jannik Abbenseth, Marc Toussaint @ IROS 2019
Mensch-Roboter-Kollaboration für schwerbehinderte Produktionsmitarbeiter
Der digitale Arbeitsplatz in der Produktion: Herausforderungen und Chancen
Wie cyber-physische Systeme zu autonomer Produktion führen
Mensch-Roboter-Kollaboration für Schwerbehinderte als Beitrag zur Inklusion in der Arbeitswelt
Inclusion Through Robotics: Designing Human-Robot Collaboration for Handicapped Workers
Adaptive Work Instructions for People with Disabilities in the Context of Human Robot Collaboration
Teilhabe durch Robotik: Ergonomische und sichere Arbeitsplätze für schwerbehinderte Produktionsmitarbeiter in der Mensch-Roboter-Kollaboration
Power-minimization and energy-reduction autonomous navigation of an omnidirectional Mecanum robot via the dynamic window approach local trajectory planning
A Predictive Online Path Planning and Optimization Approach for Cooperative Mobile Service Robot Navigation in Industrial Applications
Big-Data-Analytik: Datenbasierte Optimierung produzierender Unternehmen
A harmonized approach for constructing a robust and efficient technology backbone for agile manufacturing systems
Manufacturing Service Bus: An Implementation
Challenges of Production Microservices
Cloud-based cooperative navigation for mobile service robots in dynamic industrial environments
Energy Efficient Dynamic Window Approach for Local Path Planning in Mobile Service Robotics